

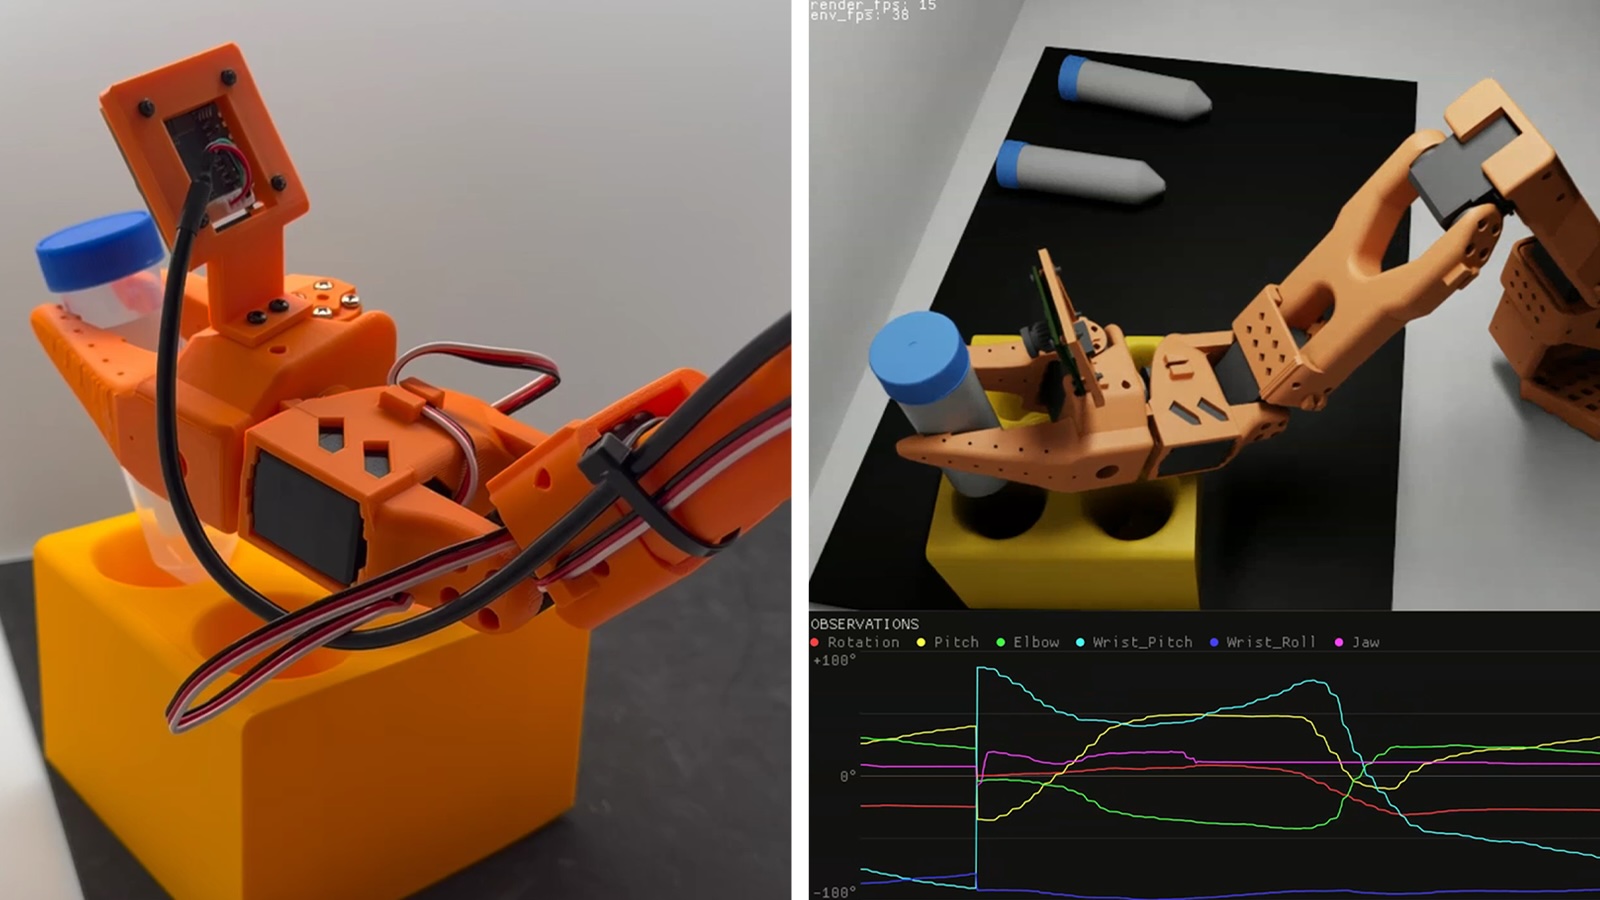
NVIDIA and Hugging Face announced on July 7 that the humanoid robot foundation model "NVIDIA Isaac GR00T 1.7" and the robot demonstration data collection framework "NVIDIA Isaac Teleop" are being integrated into LeRobot, Hugging Face's open source robotics library[1]. Integration of "NVIDIA Cosmos 3," a world model for physical AI, is also planned soon. The goal is to connect the entire robot development workflow — from data collection to model training, evaluation, and deployment — through open workflows.
Three NVIDIA Technologies Coming to LeRobot
LeRobot is Hugging Face's open source library for training, running, and sharing robot datasets, models, policies, and workflows. With this integration, the following NVIDIA technologies become directly usable from LeRobot workflows[1].
First, Isaac GR00T 1.7 is an open, reasoning VLA (Vision Language Action) model for humanoid robots — an AI model that handles vision, language, and action in an integrated way. NVIDIA positions it as the first open and commercially viable robot foundation model, making post-training and deployment easier through LeRobot workflows. Developers can adapt GR00T to new robot embodiments and tasks while checking benchmarked performance.
Next, Isaac Teleop is an open source framework for robot data collection. It lets developers capture high-quality human demonstrations from external devices in standardized, interoperable formats, then expand and share datasets with the community — all directly within LeRobot.
In addition, integration of Cosmos 3, a frontier world foundation model for physical AI, is planned. It will help developers generate and augment robotics data, simulate scenarios, and support policy development in situations where real-world data is limited or too expensive to collect[1].
Connecting Communities of 3 Million and 16 Million Developers
Through the continued partnership between NVIDIA and Hugging Face, NVIDIA's 3 million robotics developers will be connected with Hugging Face's 16 million AI builders[1]. Thomas Wolf, cofounder and chief science officer at Hugging Face, said: "Open source is how a field turns advanced research into something people can study, adapt and build on. With NVIDIA Isaac GR00T 1.7 and Isaac TeleOp in LeRobot today, robotics developers can use shared models, data and workflows to train and evaluate robots in the open"[1].
In the world of open source AI, sharing models, data, and tools has dramatically accelerated development. In robotics, however, NVIDIA points out that resources such as large datasets, robot foundation models, simulation, compute, and validation tools remain costly and fragmented, creating barriers to physical AI development[1]. This integration can be seen as an effort to lower those barriers through an open ecosystem.
Working Together with Existing NVIDIA Resources
Ahead of this integration, a broader set of NVIDIA resources was already connected to LeRobot[1]. The largest open source physical AI dataset, downloaded more than 15 million times, includes over 350,000 real and simulated trajectories and 57 million grasps, helping developers kickstart their work. Simulation frameworks based on Isaac Sim and Isaac Lab allow developers to set up environments, generate data, and validate policies before moving to physical robots.
Furthermore, through Isaac Lab-Arena in the LeRobot Environment Hub, developers can quickly prototype complex simulation environments and use them to train and evaluate generalist robot policies such as GR00T, Pi, and SmolVLA. The integration of the edge AI module Jetson Thor with the open source humanoid robot Reachy 2 also supports deployment of VLA models on real hardware[1][2].
Summary
With this announcement, Isaac GR00T 1.7 and Isaac Teleop are now integrated into LeRobot, with Cosmos 3 expected to follow soon. Developers will be able to handle everything from data collection and model adaptation to simulation validation and real-world deployment through a common open source workflow, significantly broadening access to humanoid robot development. It will be worth watching whether the rapid open-source-driven progress seen in language models can be replicated in robotics.
出典:https://blogs.nvidia.com/blog/hugging-face-lerobot-models-frameworks-open-robotics/
出典:https://huggingface.co/blog/nvidia/nvidia-isaac-teleop-and-gr00t17-in-lerobot



























